- Architecture
- Distributed microcontrollers; mission, guidance and stabilization tiers; fault isolation; safe degraded states
- Firmware
- Proprietary, controlled baseline — not open-source, not Pixhawk-derived
- Hardware
- R4 generation; compact, modular, reduced SWaP; dual IMUs; power redundancy; onboard watchdogs; sealed, anodized enclosures for high-altitude and extreme environments
- Flight functions
- Autonomous taxi, takeoff, landing, navigation and mission execution; diagnostics; mission planning
- Navigation
- Multi-constellation GNSS; tactical-grade IMU with sensor fusion; AHRS independent of GNSS; GNSS-degraded, denied and anti-spoofing operation
- Communications
- AES-256 encrypted command and telemetry; frequency-hopping spread spectrum; LOS, 4G/LTE and satellite datalinks; third-party datalink integration (pMDDL, SATCOM)
- Mission scripting
- Onboard virtual machine — custom mission logic isolated from flight-critical firmware
- Payloads
- Open payload buses and SDK-based extensions; EO/IR, SAR, SIGINT, EW, communications relay, customer-owned payloads; modular bay for rapid swap
- Energy management
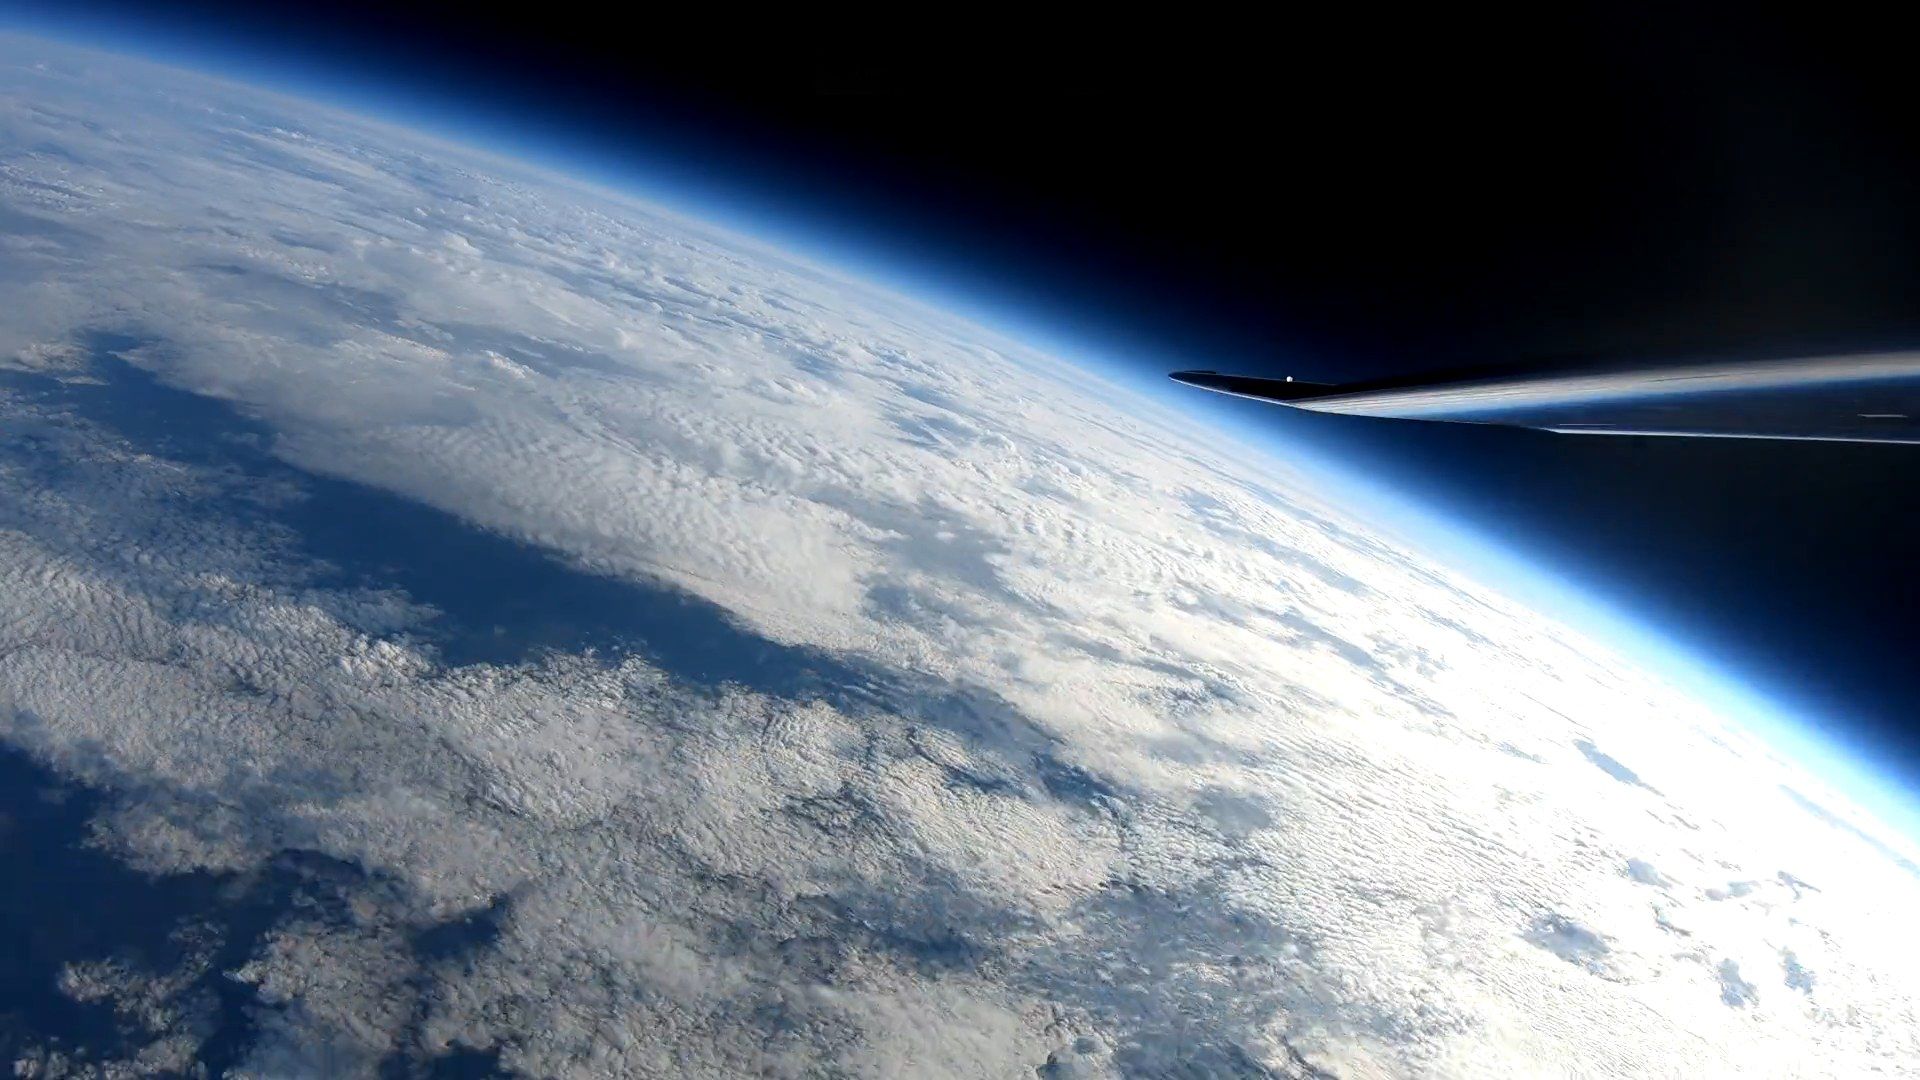
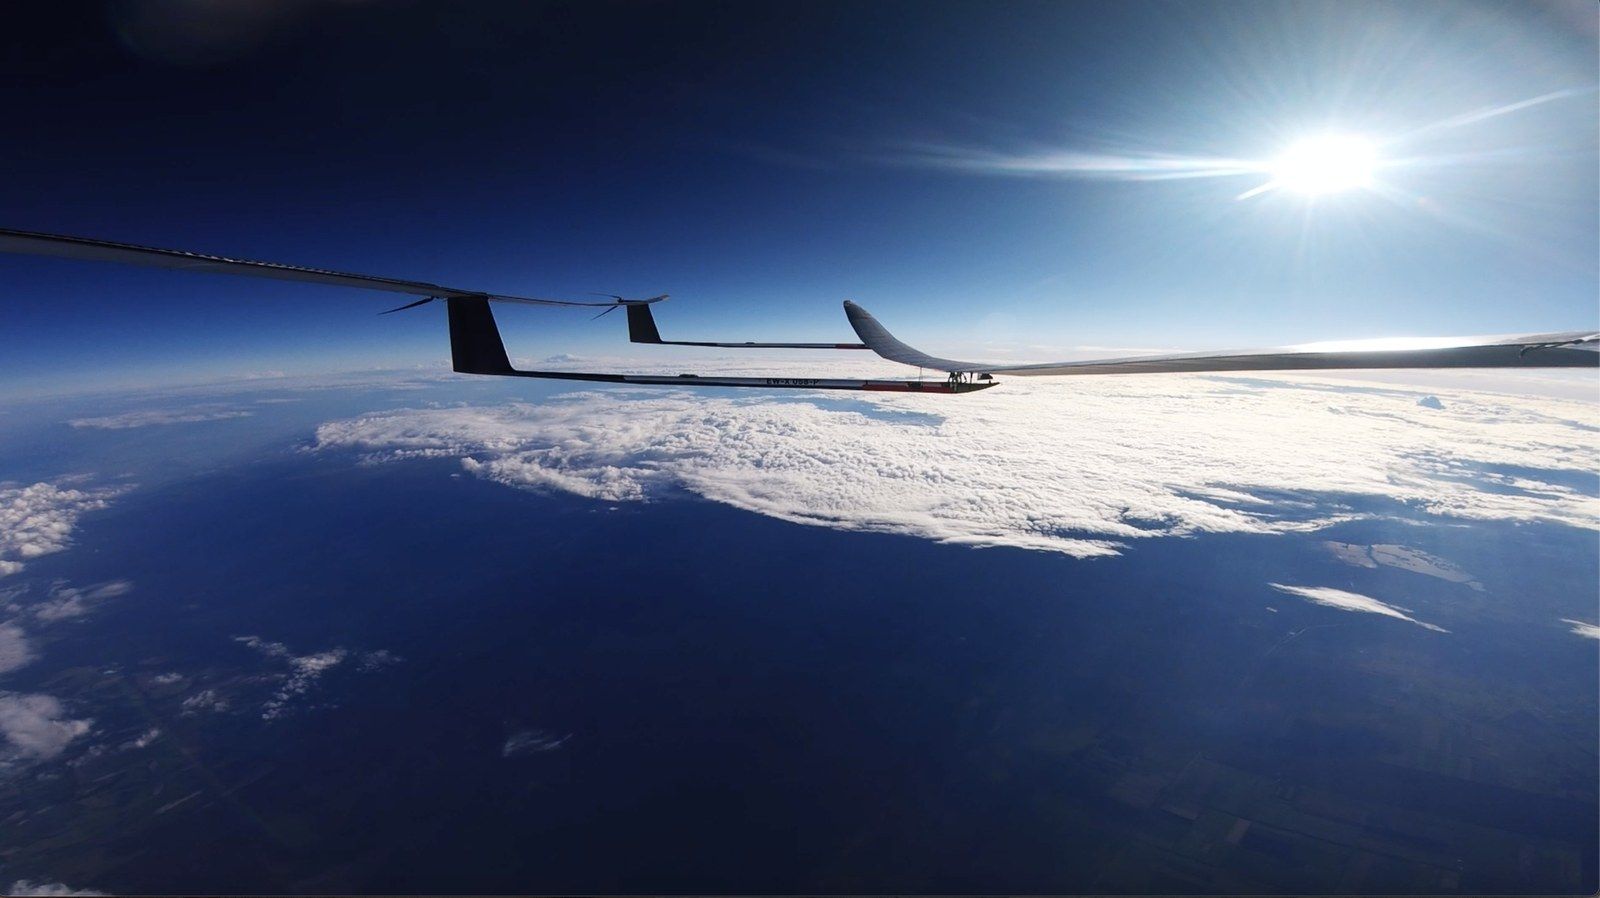
- Solar-harvesting and battery-control logic for persistent day–night stratospheric missions
- Development process
- Aligned with the DO-178C (software) and DO-254 (hardware) frameworks for safety-critical airborne systems
- Ground control
- GCS software for mission planning, real-time telemetry and command links across LOS, LTE and satellite
- Airframe classes
- Fixed-wing, rotary-wing and hybrid VTOL, from about 11 lb to 8,800 lb MTOW; also demonstrated on an uncrewed surface vessel
- Maturity
- 100,000+ cumulative flight hours across platforms; SITL and HITL validated; 5G connectivity demonstrated on a HAPS